AFTER World Model Introduces Fast–Slow Adaptation for Sudden Robot Dynamics Changes
A new arXiv paper presents AFTER, a world model that uses dual‑timescale error‑driven corrections to stay responsive.
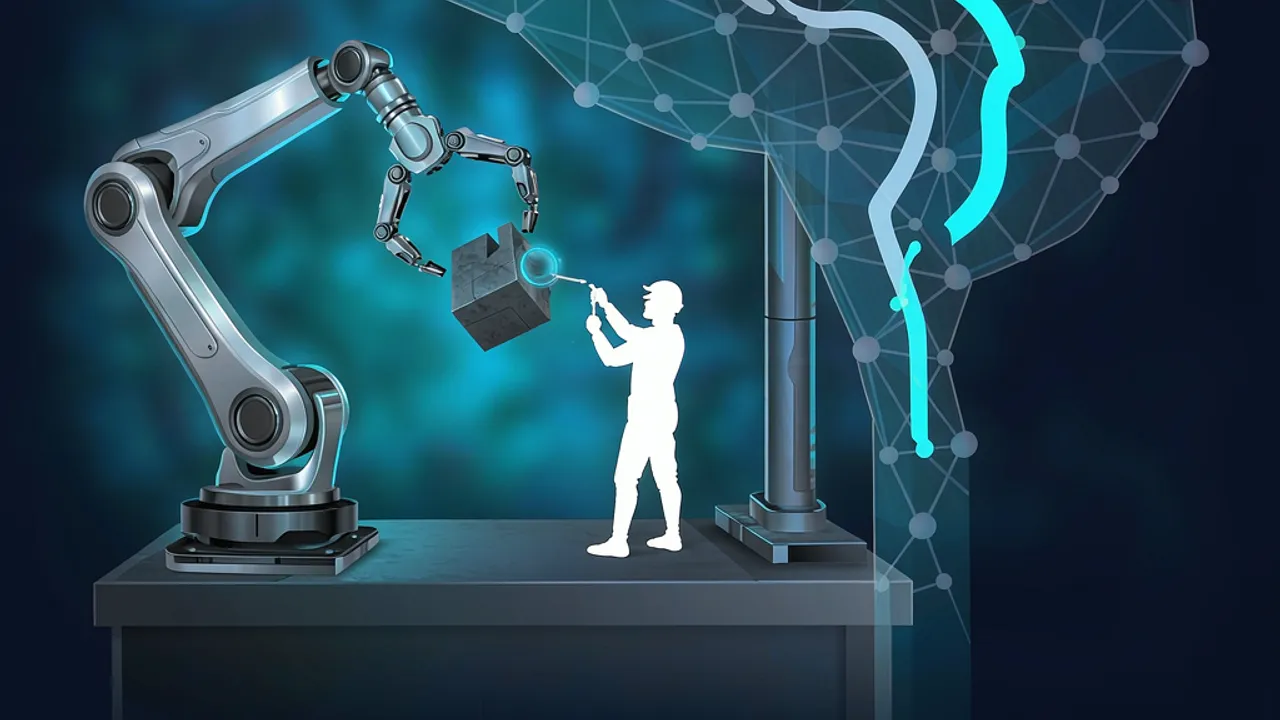 Source: Grafy Research Lab
AFTER, a world model that blends fast and slow error‑driven corrections, was unveiled in a recent arXiv pre‑print, promising robots that can instantly adjust to sudden, persistent changes in their dynamics. The work matters because existing models often trade off between reacting quickly, ignoring transient noise, and retaining learned adaptations, leading to performance drops in real‑world tasks.
What challenge does AFTER address in embodied AI?
Robotic systems frequently encounter abrupt shifts such as picking up an object with an unknown payload or experiencing a joint failure. According to the paper, these events produce "sudden, persistent, yet initially unknown changes" that cause prediction errors to compound during open‑loop rollouts, ultimately steering the robot away from its intended behavior. The authors argue that a world model must satisfy three requirements simultaneously: responsiveness (quick reaction to a change), stability (distinguishing true changes from fleeting disturbances), and persistence (maintaining the adapted dynamics when new observations are absent).
How does AFTER’s architecture differ from prior world models?
AFTER builds on three design ideas inspired by predictive coding in the human brain. First, predictive correction updates a set of pre‑trained dynamics experts at each observed step using the one‑step prediction error, without back‑propagation. Second, dual‑timescale adaptation introduces a fast correction that acts immediately but fades, alongside a slow correction that accumulates gradually and endures. Third, a routing memory adjusts the combination weights of the experts based on error signals, leaving the experts themselves untouched. This contrasts with general‑purpose models that lack dedicated adaptation, online‑adaptive models that adapt at a single timescale, and multi‑timescale models that infer slow variables only at fixed intervals.
What experimental results validate AFTER’s claims?
The authors evaluated AFTER on six datasets: five simulated robot environments (including UR5e, Hopper, and Panda) and a real‑world UAV flight‑log dataset. In every case, AFTER achieved a lower multi‑step mean error than all ten baseline models. The paper reports that its error was 16 %–34 % lower than the strongest competitor across the datasets, and it achieved the highest mean return in a joint‑failure control task. Notably, the advantage persisted from the first step after a change up to step‑40, demonstrating the model’s responsiveness, stability, and persistence in a single metric.
Which components of AFTER contribute most to its performance?
Ablation studies in the paper isolate each design element. Removing the fast correction degrades early‑step accuracy, confirming its role in responsiveness. Disabling the slow correction leads to larger errors under transient disturbances, highlighting its stabilizing effect. Finally, fixing the expert combination weights (i.e., removing the routing memory) reduces long‑term accuracy, showing that dynamic weighting supports persistence. Together, the three mechanisms create a division of labor where fast memory handles immediate error spikes, slow memory filters out noise, and the routing memory reallocates trust among experts as the robot’s dynamics evolve.
How can creators and researchers explore AFTER with Grafy?
While Grafy does not yet host a dedicated AFTER implementation, the Reader app lets you upload the arXiv PDF and query the paper directly, turning dense sections into concise explanations. You can also experiment with the underlying ideas using Chat to prototype pseudo‑code for the fast‑slow update rules, or to brainstorm how to integrate a routing memory into existing world‑model pipelines. Those interested in reproducing the experiments can store the released code and datasets in Grafy Files, then run simulations in Code to compare AFTER against baseline models.
Source: https://arxiv.org/abs/2611.15215
Frequently asked questions
How does AFTER achieve responsiveness without sacrificing stability?
AFTER uses a fast correction that updates instantly from the one‑step prediction error, reducing error spikes right after a change. At the same time, a slower correction accumulates more gradually, so brief disturbances do not cause large weight shifts. This separation lets the model react quickly while ignoring transient noise.
Does AFTER modify the pre‑trained expert models during adaptation?
No. The experts remain frozen; ONLY the fast and slow memory states and the routing memory’s combination weights are updated online based on error signals. This preserves the original expertise while allowing flexible re‑weighting.
Can the dual‑timescale mechanism be applied to other AI domains beyond robotics?
Yes. Any sequential prediction task that experiences sudden, lasting shifts—such as time‑series forecasting or video prediction—could benefit from a fast correction for immediate anomalies and a slow correction for lasting regime changes. Implementing the same memory architecture would follow the same error‑driven update principles described in the paper.
More news
OpenAI dissolves its dedicated robotics team to fold researchers into general AI groups
OpenAI has disbanded its stand‑alone robotics unit, moving staff to core research and applied groups as its GPT‑6 Astra model begins controlling robots.
Cmpnd launches dspy-wsp: weight‑space programming
Cmpnd released dspy-wsp, a prototype DSPy optimizer that edits model weights directly without gradients.
Lovable AI platform lets thousands of apps expose passport data and private messages
A Crissy Field security analysis of 159,041 Lovable projects found thousands of apps leaking emails.