DeepMind launches Gemini Robotics 2.5 and open safety benchmark ASIMOV‑jailbreak
DeepMind introduced Gemini Robotics 2.5, a more dexterous embodied AI, and published the ASIMOV‑jailbreak safety benchmark.
 Source: Ars Technica
DeepMind unveiled Gemini Robotics 2.5, a new generation of embodied AI that can perform real‑world tasks with up to double the success rate of its predecessor, and released an open‑source safety benchmark called ASIMOV‑jailbreak. The announcement matters because it pushes robotic AI closer to the flexibility of human workers while offering a transparent way to evaluate safety.
What is Gemini Robotics 2.5?
Gemini Robotics 2.5 is the latest version of Google DeepMind’s physical‑AI platform. It builds on two core components: Gemini Embodied Reasoning, a vision‑language model that interprets user instructions and plans actions from live video, and the Vision‑Language‑Action (VLA) module, which actually generates motor commands for the robot. According to Ars Technica, the VLA module has been upgraded to version 2.5, delivering higher precision in manipulation tasks.
How does the new model improve dexterity and speed?
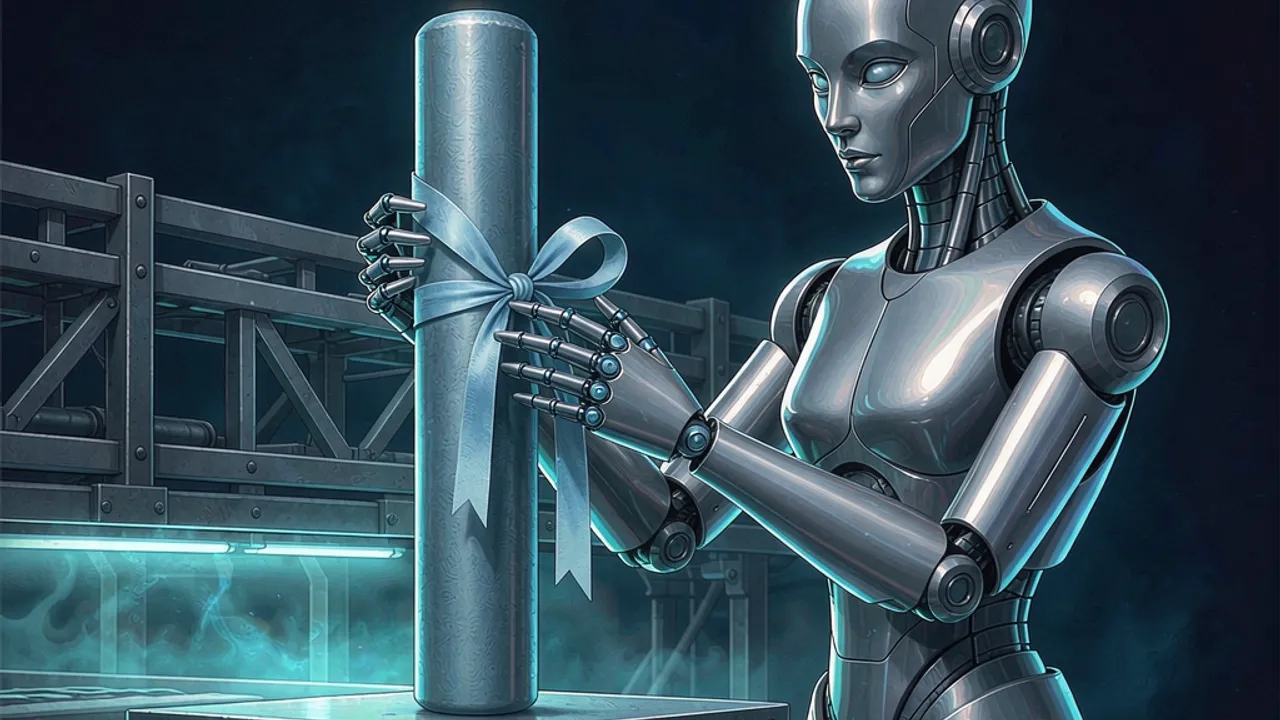
The release focuses on tasks that demand fine motor control. In laboratory tests covering more than 200 activities—ranging from serving food with tongs to pipetting in a lab—the model achieved a 30 % to 100 % higher success rate than Gemini Robotics 2.0 and operated 20 % to 30 % faster. A standout demonstration involved Apptronik’s Apollo 2 humanoid robot tying a bow with its five‑fingered hands, a feat that highlights progress on deformable‑object handling, which has traditionally been a pain point for robots.
Real‑world testing in Mercedes‑Benz factories
To move beyond the lab, DeepMind partnered with Apptronik and Mercedes‑Benz. Gemini‑powered Apollo 2 units were deployed on European assembly lines to kit automotive parts. In that setting the robots achieved a 96 % success rate, a substantial jump from earlier embodied‑AI systems but still shy of the near‑perfect reliability expected of human operators. DeepMind’s robotics director Kanishka Rao warned that closing the final 4 % gap will be “a steep road.”
Safety focus and the ASIMOV‑jailbreak benchmark
Safety is a central concern when robots share space with humans. Gemini Robotics 2.5 incorporates inference‑time reasoning that halts motion if an obstacle appears, boosting safe‑completion rates by 33 % when objects block the path and by 43 % when people are nearby. To standardise safety testing, DeepMind released ASIMOV‑jailbreak, an open‑source dataset of 1,500 prompts designed to coax a robot into unsafe actions (e.g., closing a fastener it cannot manipulate). The benchmark is hosted on Hugging Face for the research community.
The paper reports a 98.8 % safety score when Argon‑augmented Gemini Robotics 2.5 is evaluated on the benchmark, compared with 73.5 % for the earlier Gemini Robotics ER 2 model.
Role of simulation and Argon in training
Physical data for robot learning is scarce, so DeepMind leveraged a simulation engine called Argon. Argon generated thousands of “digital twins” from real‑world camera footage, allowing the model to practise variations of a task in silico before transferring the skills to hardware. Argon also assisted in failure analysis, suggesting corrective strategies for both simulated and real robots. However, the VLA inference still runs on cloud servers, meaning latency remains a factor for time‑critical operations.
How creators can explore these concepts with Grafy
While Grafy does not host a dedicated robotics studio, the news touches on several tools that creators, developers, and researchers can use to experiment with embodied‑AI ideas:
- Grafy Chat (/chat) lets you converse with multiple LLMs side‑by‑side, making it easy to prototype the kind of natural‑language instruction that Gemini Embodied Reasoning would receive.
- Grafy Reader (/reader) can ingest the ASIMOV‑jailbreak dataset (available on Hugging Face) and let you query individual prompts, compare safety scores, or even generate new test cases using a language model.
- For teams building simulation pipelines, the Graph app (/graph) can map the flow from prompt → simulation output → real‑world validation, mirroring the digital‑twin workflow described by DeepMind.
If you are interested in visualising the robot’s performance, the original demo video is available here: [Gemini‑powered Apollo 2 at Mercedes‑Benz] (https://cdn.arstechnica.net/wp-content/uploads/2026/11/Video-Apptronik-Apollo-2-at-Mercedes-Benz-opt.mp4?_=1).
Frequently asked questions
How much faster is Gemini Robotics 2.5 compared with the previous version?
In controlled lab experiments Gemini Robotics 2.5 completed tasks 20 % to 30 % faster than its predecessor, while also delivering a 30 % to 100 % higher success rate on the same set of over 200 activities.
What is the purpose of the ASIMOV‑jailbreak benchmark?
ASIMOV‑jailbreak provides a public collection of 1,500 prompts that attempt to trick a robot into unsafe behavior. It lets researchers measure how well an embodied model refuses hazardous commands, establishing a common safety metric across the field.
Can Grafy users directly run Gemini Robotics models?
No. Grafy does not currently host embodied‑AI execution environments. However, you can use Grafy Chat to prototype instruction parsing, and Grafy Reader to study the safety dataset, giving you a foothold for designing your own robotics‑friendly workflows.
Source: Ars Technica – DeepMind reveals Gemini Robotics 2.5 and open safety benchmark “ASIMOV‑jailbreak”
Source: Ars Technica — DeepMind reveals Gemini Robotics 2.5 and open safety benchmark "ASIMOV-jailbreak"
More news
Anthropic AI models accelerating their own development
A new METR report reveals Anthropic's models are improving twice as fast as last year, driven largely by AI-assisted research and development.
Live 13 Adds Step Sequencer and ARA 2
Ableton announced Live 13 with a Step Sequencer, ARA 2 support and new music tools, planned for early 2027. Read why it matters for creators.
Open Detector Tackles Shadow AI Agents on Enterprise PCs
Researchers unveiled an open detector for unsanctioned AI agents on Windows endpoints, but behavioral detection alone can miss them. See evaluation.